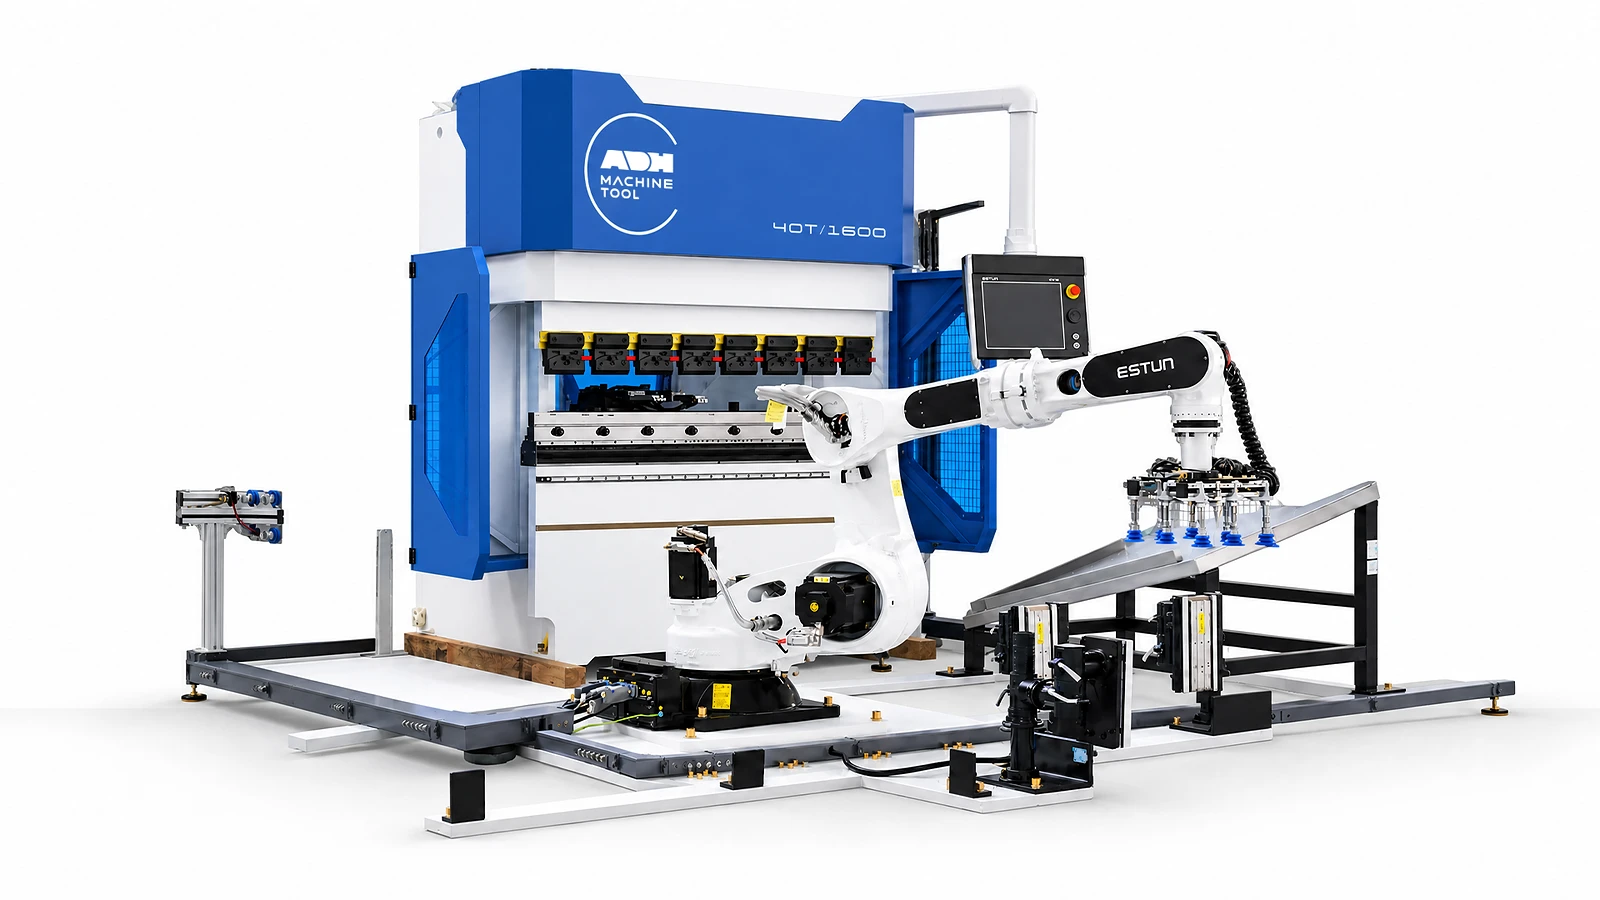
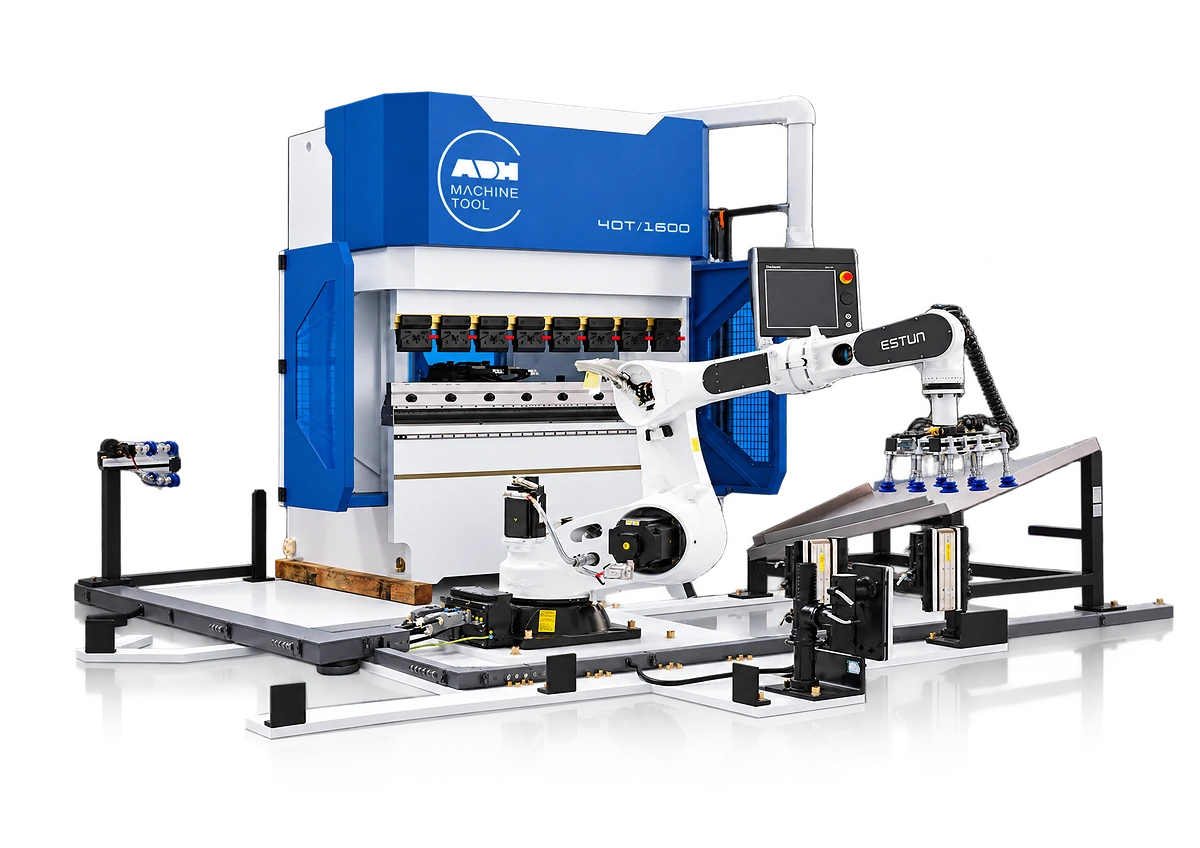
Robotic press-brake cell
Coordinate the machine and the robot.
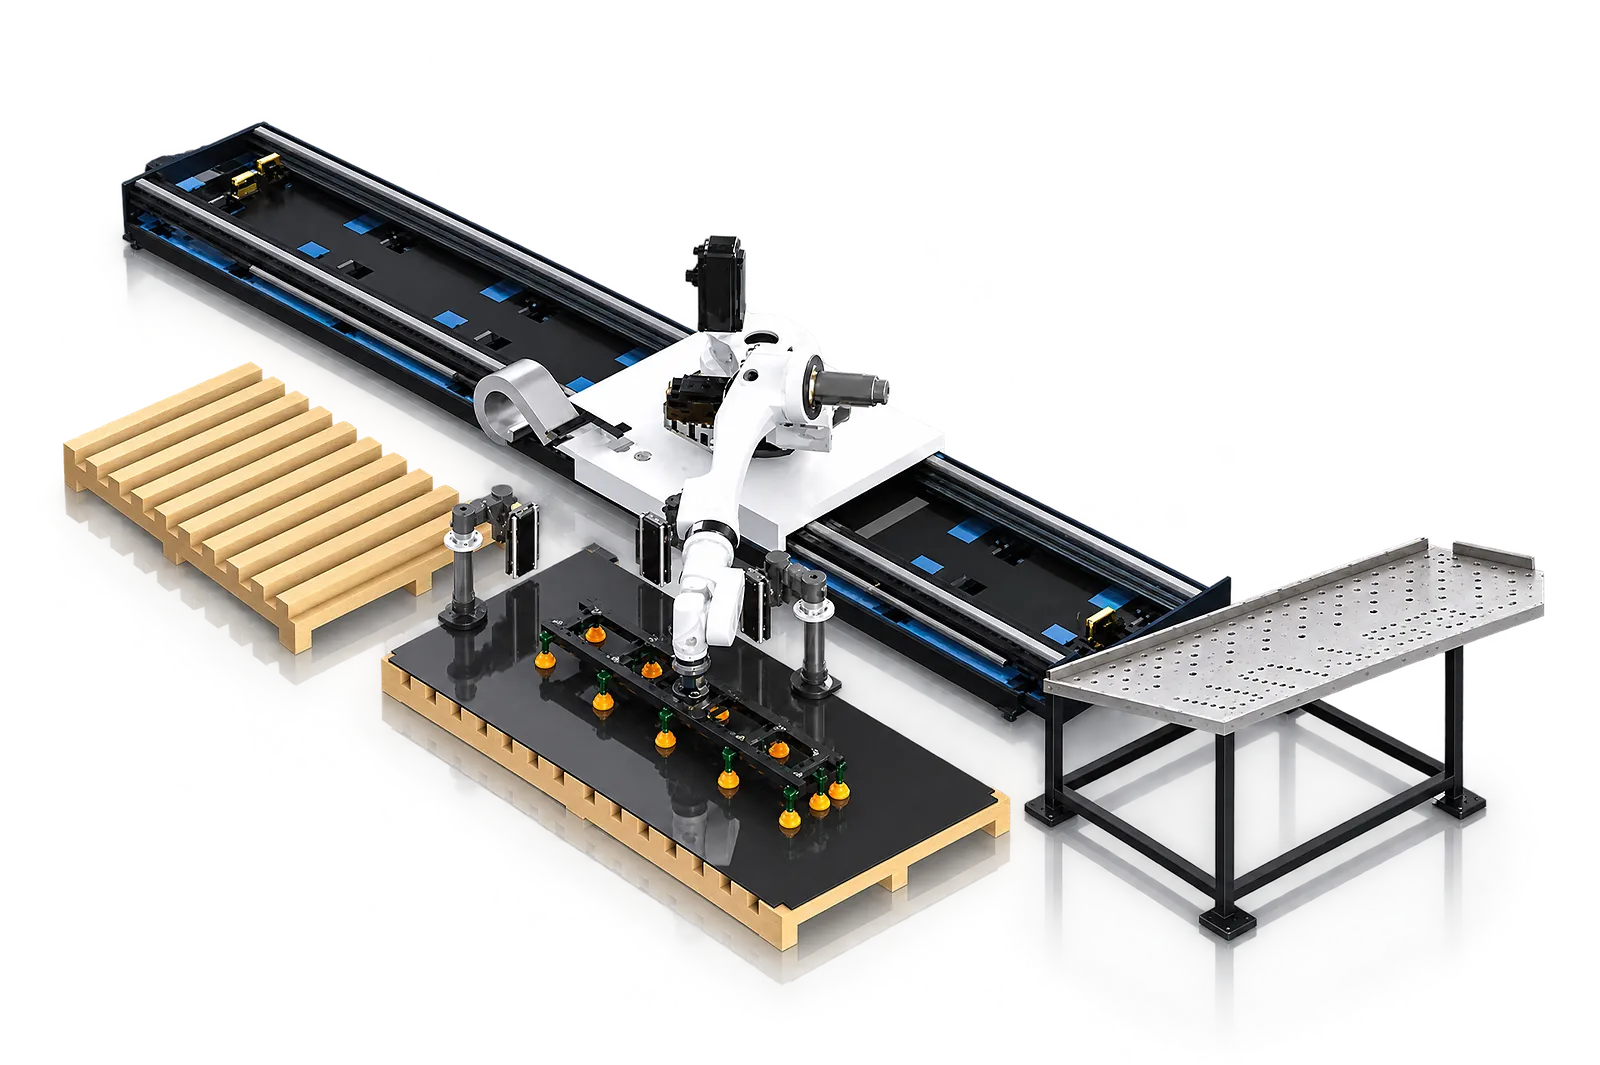
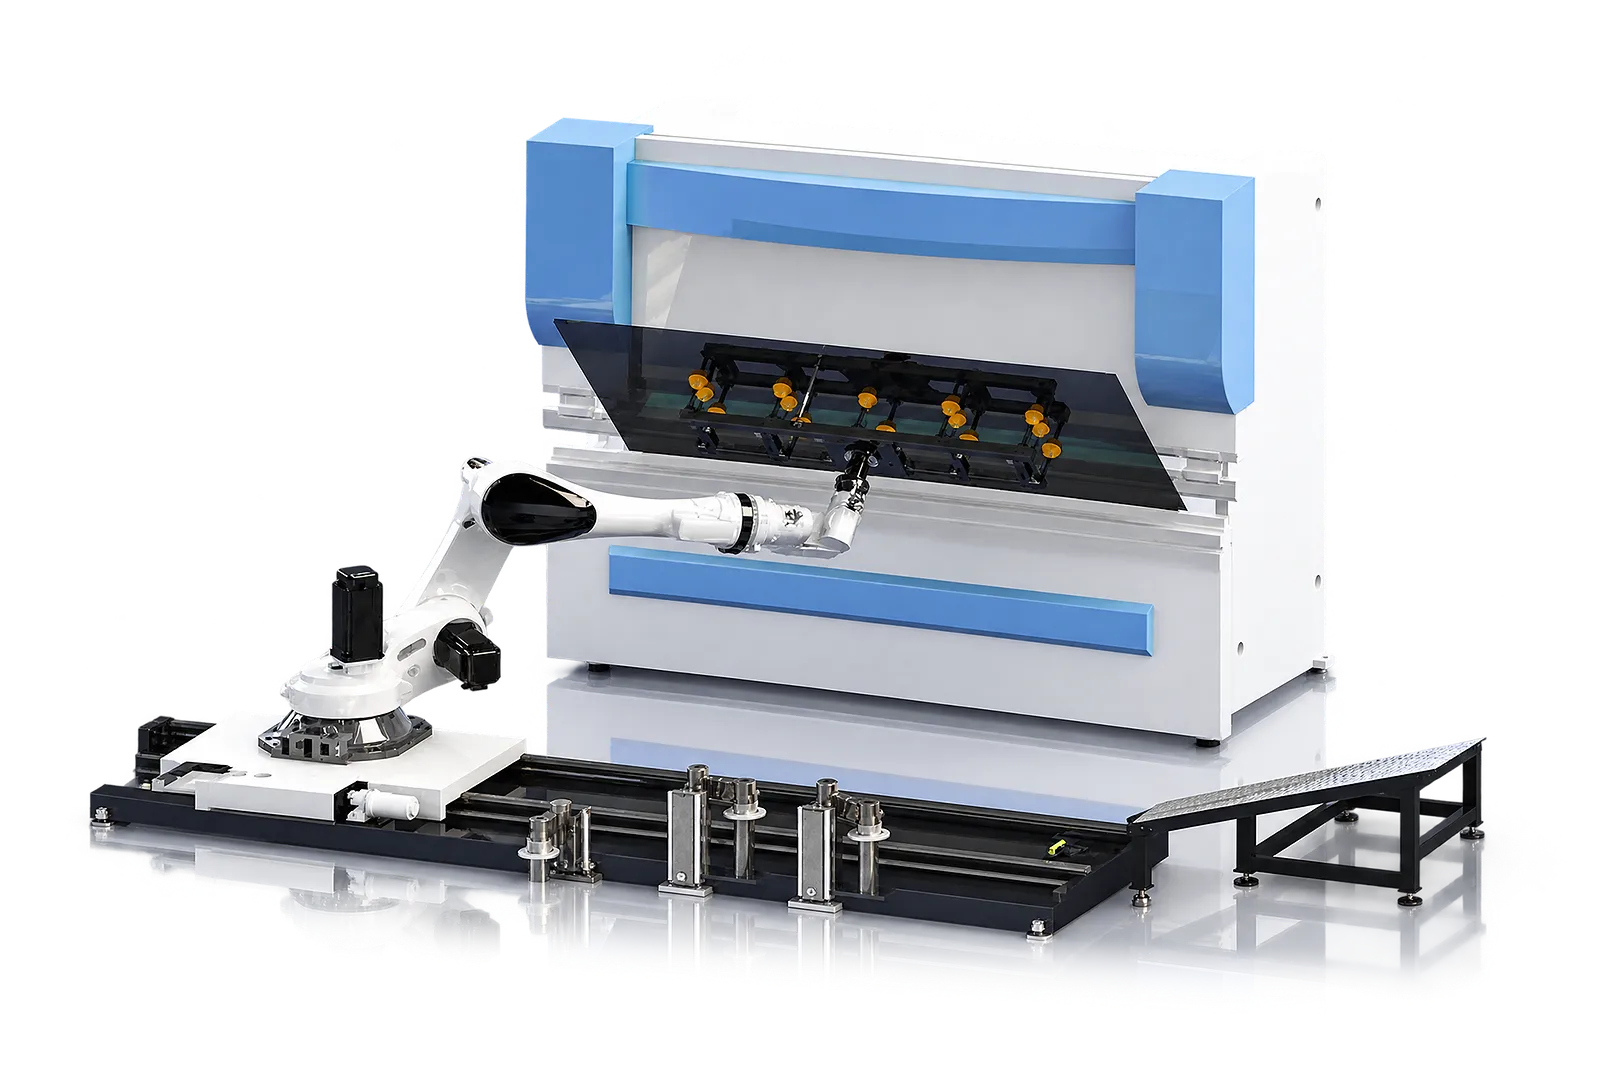
Match the bending host, gripper, reference stations and part turns to your representative part family.
Discuss This Configuration →Details & specifications
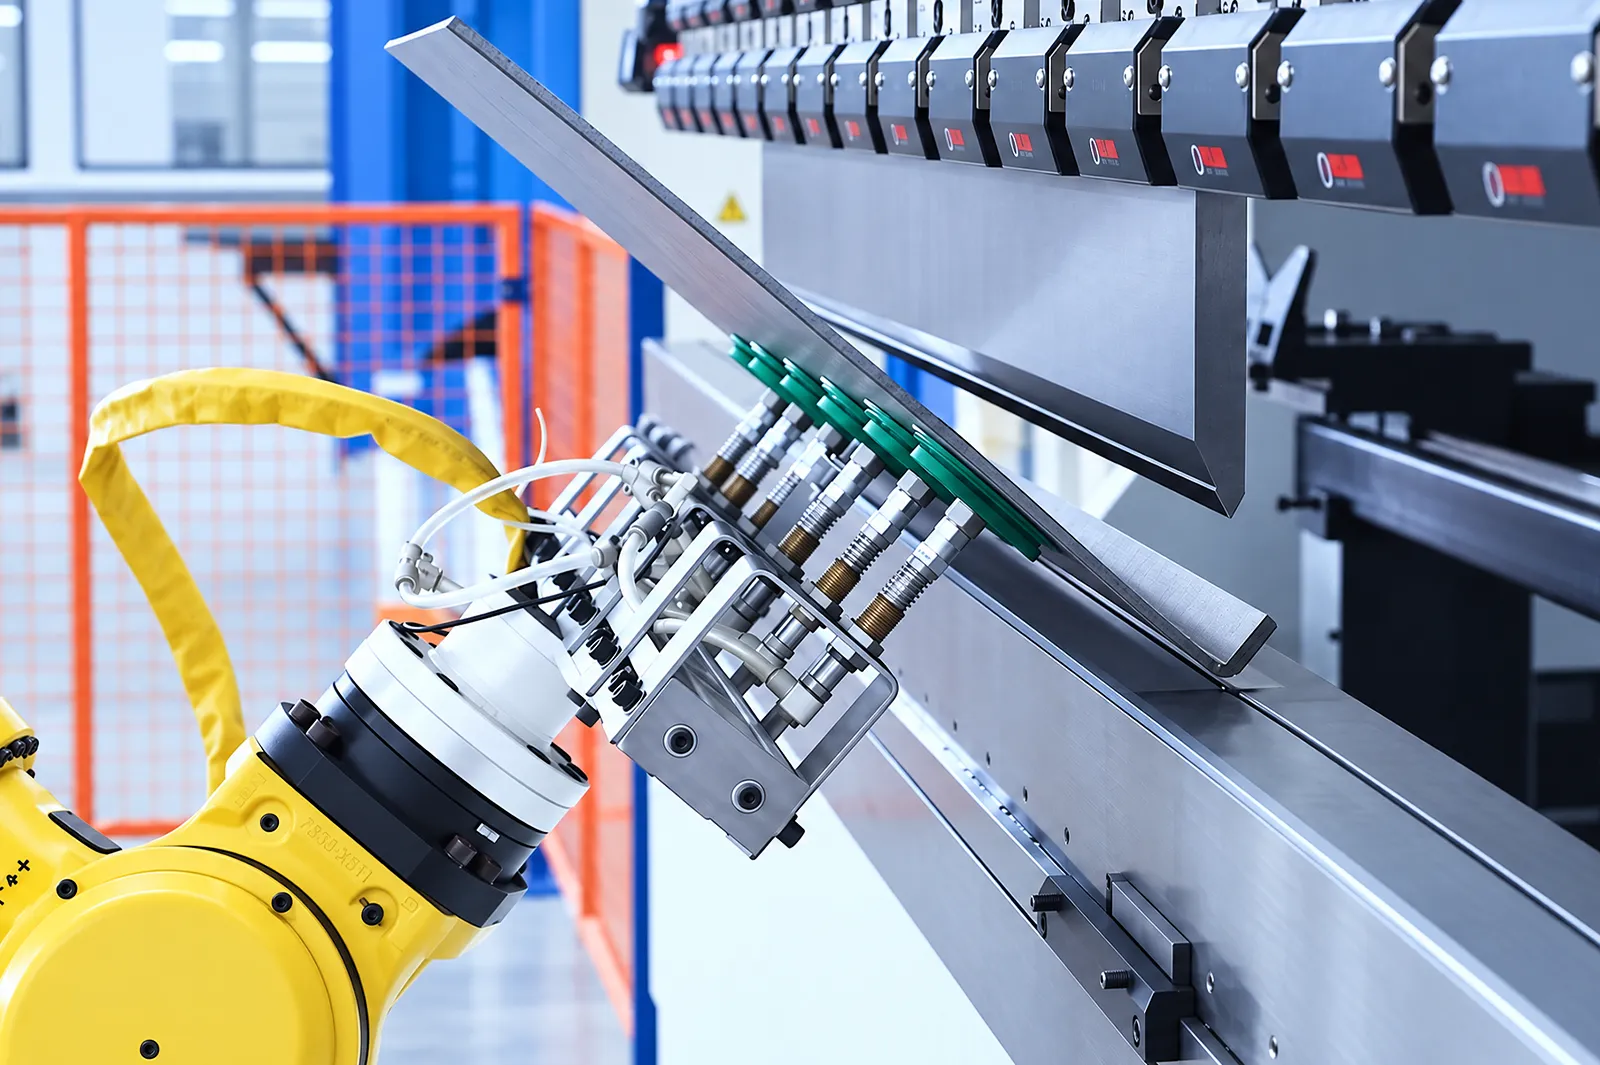
The WADG host supplies the bending force, tooling clearance and stroke. Size the robot for part plus gripper at the required reach. Referencing, turnover and stacking stations determine the moves and cycle time. Review the complete cell configuration.
Compare WADG host models →